
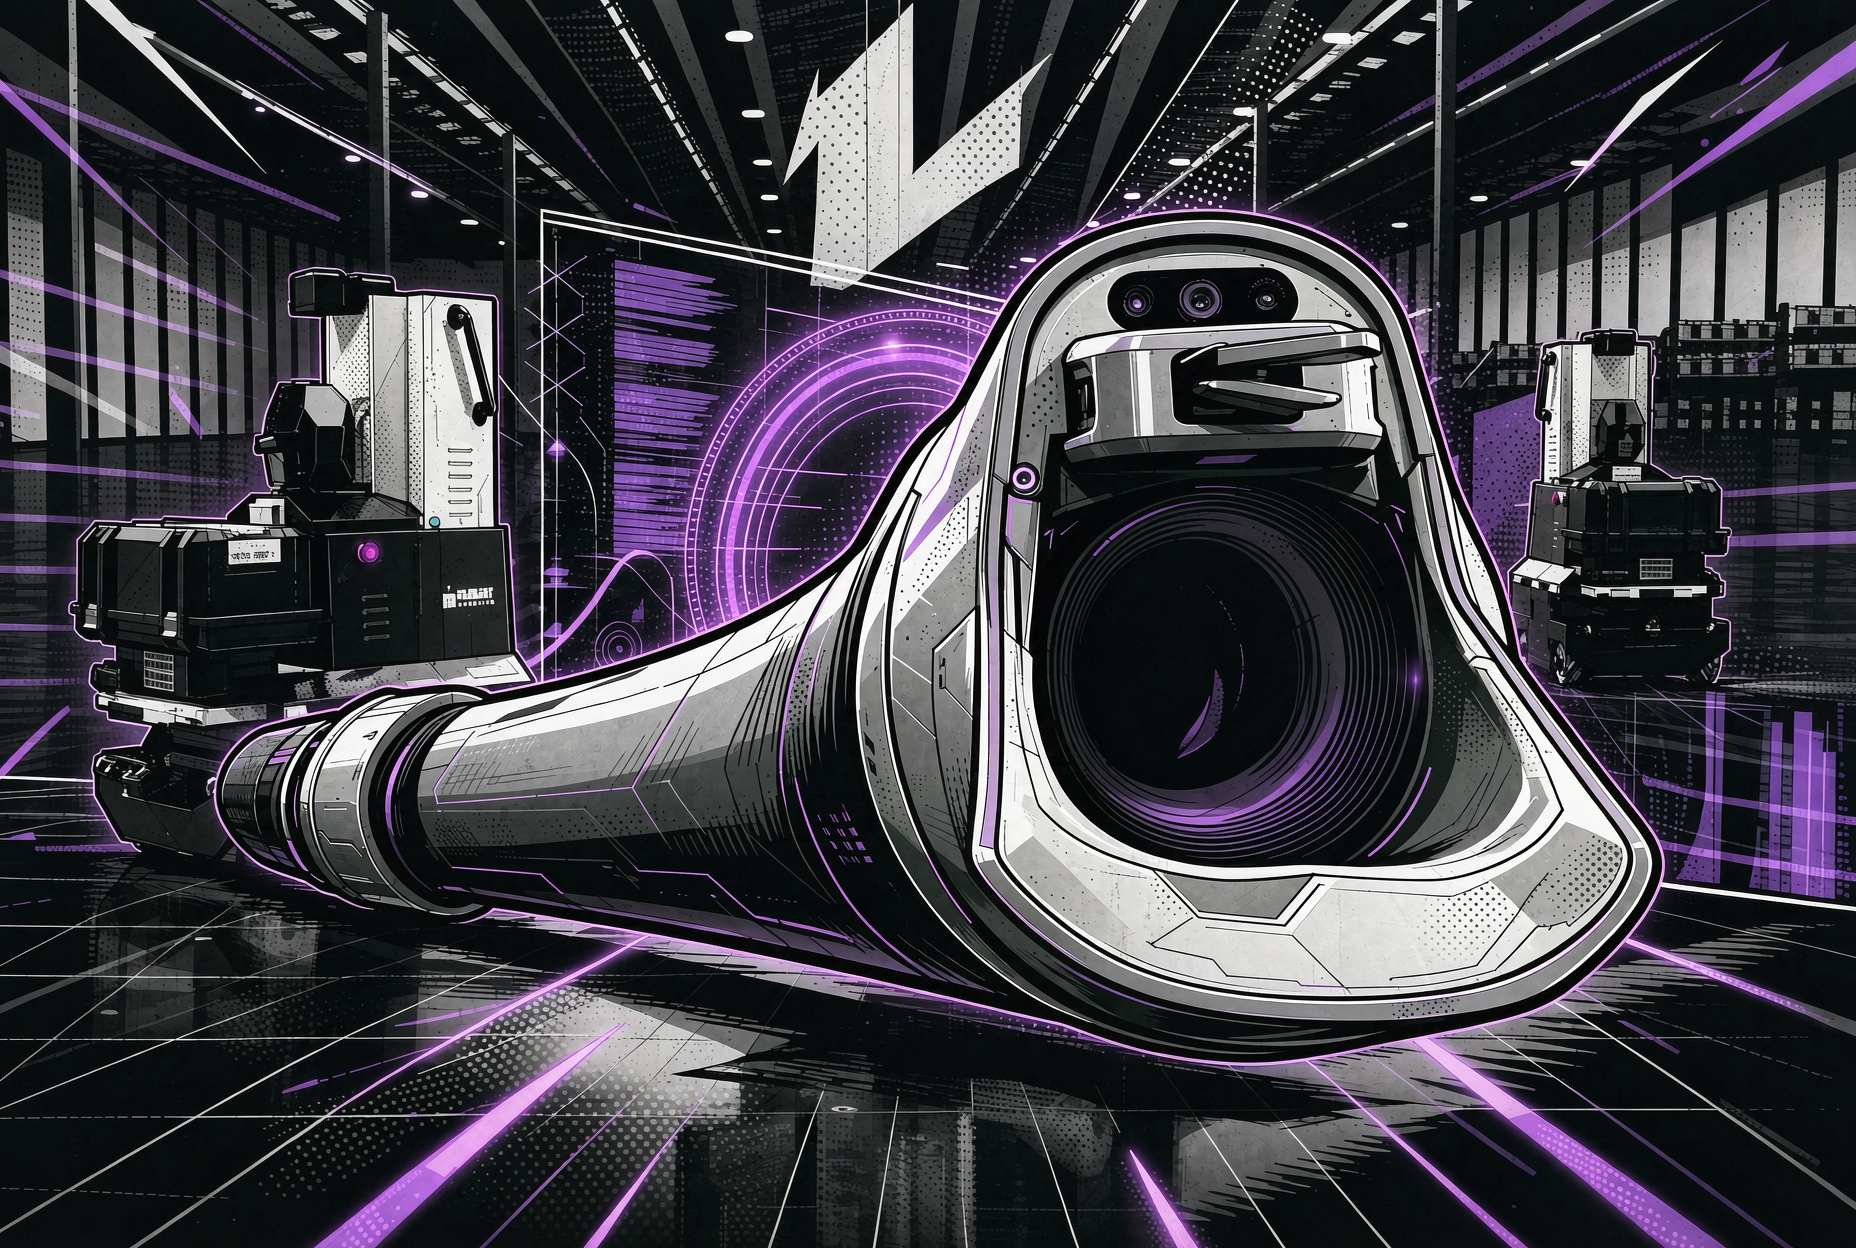
以色列初创公司Picker AgRobotics正在开发一种机器人水果采摘系统,使用中空的柔性臂,设计用于穿过树枝、从茎部切下水果,并直接将其转移到现有的采收箱中。与抓取放置式采摘机器人不同,该系统不使用夹爪,也不在采摘每个水果后缩回手臂。相反,茎被切断,水果通过中空臂移动到箱子里。该公司表示,这种方法允许系统在现有果园布局中工作,不需要高密度种植、棚架或特定的树形结构。
Israeli startup Picker AgRobotics is developing a robotic fruit-picking system that uses a hollow flexible arm designed to pass through branches, cut fruit from the stem, and transfer it directly into existing harvest bins. Unlike pick-and-place harvesting robots, the system does not use grippers and does not retract its arm after picking each fruit. Instead, the stem is cut and the fruit moves through the hollow arm into the bin. The company says this approach allows the system to work in existing orchard layouts without requiring high-density planting, trellises, or specific tree forms.
最初测试牛油果
该技术最初在牛油果上测试,因为树的大小、树冠深度以及区分绿色果实和叶子的难度。该公司也瞄准橙子、柠檬、梨和苹果。Picker AgRobotics的目标是采摘一棵树上95%的水果。据联合创始人兼CEO Yossi Rosenblum称,现有的短而刚性的机械臂在该公司瞄准的果园条件下只能达到约30%。该系统将机器人采摘与基于AI的视觉模型相结合,评估单个水果的成熟度、大小和质量。采收数据还可以与单棵树关联,提供关于已采收水果和树冠中剩余水果的信息。
Initially tested on avocados
The technology was initially tested on avocados because of tree size, canopy depth, and the difficulty of distinguishing green fruit from leaves. The company is also targeting oranges, lemons, pears, and apples. Picker AgRobotics aims to pick 95% of the fruit on a tree. According to co-founder and CEO Yossi Rosenblum, existing short, rigid robotic arms can achieve only about 30% under the orchard conditions the company is targeting. The system combines robotic picking with AI-based vision models that assess the ripeness, size, and quality of individual fruits. Harvest data can also be linked to individual trees, providing information about harvested fruit and fruit remaining in the canopy.
成本目标
该公司估计,加利福尼亚中央山谷的柑橘采收目前报价为每900磅水果箱25美元,使用其系统可以降至20美元。其初始模型的目标是采收成本比当前人工采收成本低20%,如果种植者购买设备,则比人工劳动低50%。这些单元可以被拖曳或连接到拖拉机上,一个拖拉机操作员或自主车辆可能操作四到五个单元。该公司计划最初通过租赁提供机器,然后再增加购买选项。
Cost targets
The company estimates that citrus harvesting in California's Central Valley is currently quoted at $25 per 900-pound fruit bin, and that using its system this could be reduced to $20. Its initial model targets a harvesting cost 20% lower than current manual harvesting costs, and 50% lower than manual labor if growers purchase the equipment. The units can be towed or attached to a tractor, and one tractor operator or autonomous vehicle could potentially operate four to five units. The company plans to initially offer the machines through leasing, then add a purchase option.
试点计划
该系统已经建造并在果园中测试了四代。客户试点计划于2027年1月开始,从以色列开始,然后扩展到加利福尼亚,可能还有西班牙。采摘机器人是农业自动化里一个进展比较慢的方向。水果的形状、大小、颜色、成熟度每次都不一样,树枝和叶子的遮挡让视觉识别变得复杂。Picker AgRobotics的中空柔性臂方案绕开了抓取这个最难的环节,用切断果茎、让水果通过管道落入箱子的方式简化了动作。95%的覆盖率目标对应的是现有刚性机械臂30%的水平,如果真能做到,采摘机器人的经济性会完全不同。接下来要看的是,2027年1月开始的客户试点能不能在真实果园里稳定运行。
Pilot program
The system has already been built and tested in orchards across four generations. A customer pilot program is scheduled to begin in January 2027, starting in Israel and then expanding to California and possibly Spain. Picking robots are a relatively slow-moving direction in agricultural automation. The shape, size, color, and ripeness of fruit differ every time, and occlusion by branches and leaves makes visual recognition complex. Picker AgRobotics' hollow flexible arm approach bypasses grasping, the most difficult link, and simplifies the action by cutting the fruit stem and letting the fruit fall through a tube into the bin. The 95% coverage target corresponds to the 30% level of existing rigid robotic arms. If it can truly be achieved, the economics of picking robots will be completely different. What to watch next is whether the customer pilot beginning in January 2027 can operate stably in real orchards.


